Leading Software Engineer (Senior Capstone Project)
Waste Treatment Completion Company, Richland, WA. (Remote)
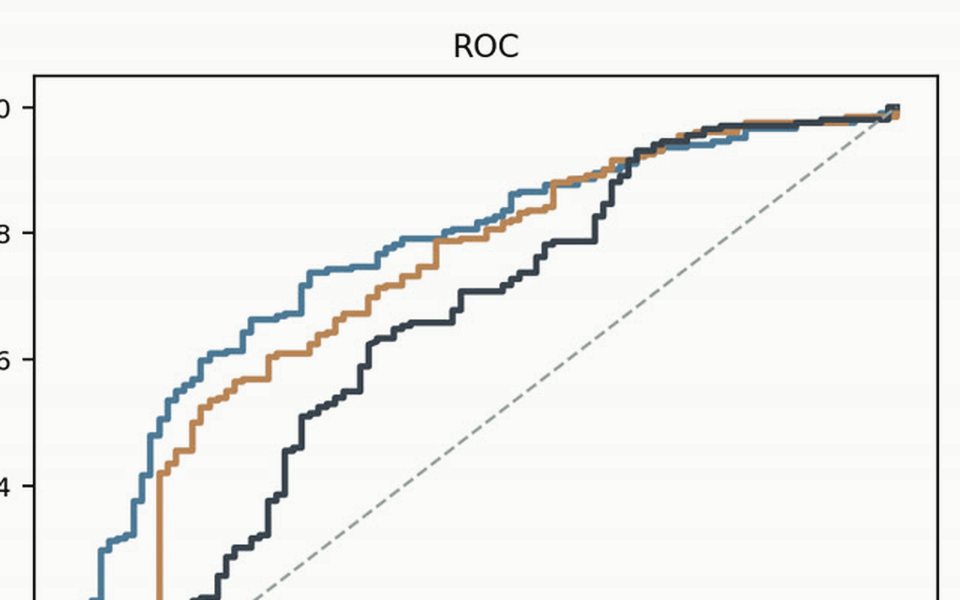
Lead technical developer for a Python application processing safety-critical calculations for Hanford radioactive waste vitrification. Developed data-analysis pipelines focused on auditability, consistency, and maintainability; documented the implementation and created the developer handover document; managed the student team through task delegation and conflict resolution.